What is the device being asked to do?
A task describes intended work. Its digital authorization has a defined scope.
EDGE + DEVICE BOUNDARIES
Embedded AI brings intelligence into products, machines and edge systems. That proximity makes local execution control important because a device may act even when a cloud service is distant, delayed or unavailable.
Embedded AI safety is an application area for control and accountability inside or near devices, rather than an additional technology family. WisdomLink™ explores permission at each consequential boundary without assuming that an upstream authorization transfers to a local action.
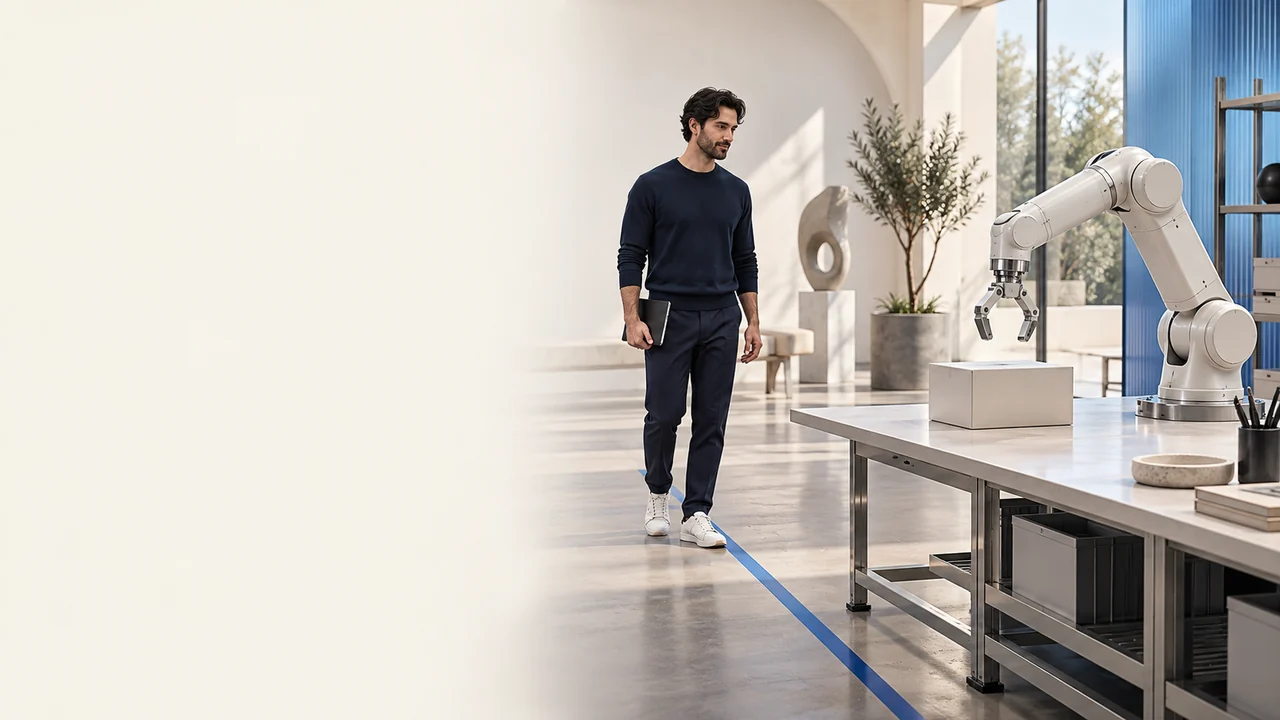
Consider a robot with intelligence close to the device. Its task remains available, but a person enters the shared workspace before the next movement.
The public design objective is to keep the consequential action subject to its own permission boundary, including when intelligence is distributed across systems.
This is a comparison of responsibilities, not a hardware layout.
A task describes intended work. Its digital authorization has a defined scope.
Motion, force or energy presents a separate permission question under current conditions.
WisdomLink™ explores boundary-specific design IP for embedded and edge systems. Digital approval does not automatically grant physical permission; a restart also requires a fresh resumption decision. Device-specific integration and evaluation belong to a separate engineering discussion.
Development stage. WisdomLink™ is developing patent-pending design IP. This page explains public purpose and illustrative use; protected implementation details are not disclosed.
Robot OS considers tasks and surroundings; Mobility OS considers operating environments and control authority; IronSwarm considers cooperation among autonomous systems; IronGrid considers safe wireless power allocation. These are distinct families relevant to embedded and edge applications, not a required stack.